














Robot code4322/2025_Robot
Latest commitApr 18 · make 2 coral center left faster
Built for REEFSCAPE, the 2025 FIRST Robotics Competition game.

Nothing selected. Turn on Season, Champs or Offseason to see performance.
| Point | xP (Match 13) | Rank | Event best xP |
|---|---|---|---|
| Going into the season | 35.9 | — | — |
| Los Angeles Regional | 46.8 | 10 of 43 | 85.5 |
| Central Valley Regional | 58.8 | 12 of 42 | 90.5 |
| Milstein Division | 68.9 | 32 of 75 | 99.9 |

Beneath the ocean’s surface lies our planet’s most complex ecosystems, full of life and potential for exploration and learning, where each inhabitant has a role to play in building a thriving environment.
During the 2024-2025 FIRST® season, FIRST® DIVE℠ presented by Qualcomm, teams will use their STEM and collaboration skills to explore life beneath the surface of the ocean. Along the way, we’ll uncover the potential in each of us to strengthen our community and innovate for a better world with healthy oceans.
Match results appear here from The Blue Alliance.
| Match | Alliances | Result | Video |
|---|---|---|---|
 | Red alliance:score 216 Blue alliance with 4322:score 192 | LossRed won | Watch |
 | Red alliance with 4322:score 209 Blue alliance:score 237 | LossBlue won | Watch |
 | Red alliance with 4322:score 171 Blue alliance:score 155 | WinRed won | Watch |
 | Red alliance:score 157 Blue alliance with 4322:score 174 | WinBlue won | Watch |
 | Red alliance:score 113 Blue alliance with 4322:score 200 | WinBlue won | Watch |
 | Red alliance with 4322:score 198 Blue alliance:score 216 | LossBlue won | Watch |
 | Red alliance with 4322:score 119 Blue alliance:score 261 | LossBlue won | Watch |
 | Red alliance:score 223 Blue alliance with 4322:score 210 | LossRed won | Watch |
 | Red alliance:score 193 Blue alliance with 4322:score 182 | LossRed won | Watch |
 | Red alliance:score 203 Blue alliance with 4322:score 204 | WinBlue won | Watch |
Match 13| Match | Alliances | Result | Video |
|---|---|---|---|
 | Red alliance:score 148 Blue alliance with 4322:score 96 | LossRed won | Watch |
 | Red alliance with 4322:score 123 Blue alliance:score 104 | WinRed won | Watch |
 | Red alliance:score 63 Blue alliance with 4322:score 135 | WinBlue won | Watch |
 | Red alliance with 4322:score 163 Blue alliance:score 134 | WinRed won | Watch |
Red alliance with 4322:score 190 Blue alliance:score 195 | LossBlue won | — | |
Red alliance with 4322:score 116 Blue alliance:score 76 | WinRed won | — | |
Red alliance:score 140 Blue alliance with 4322:score 181 | WinBlue won | — | |
Red alliance with 4322:score 125 Blue alliance:score 109 | WinRed won | — | |
 | Red alliance with 4322:score 97 Blue alliance:score 127 | LossBlue won | Watch |
 | Red alliance:score 151 Blue alliance with 4322:score 109 | LossRed won | Watch |
 | Red alliance:score 116 Blue alliance with 4322:score 165 | WinBlue won | Watch |
 | Red alliance:score 155 Blue alliance with 4322:score 177 | WinBlue won | Watch |
 | Red alliance:score 185 Blue alliance with 4322:score 170 | LossRed won | Watch |
 | Red alliance with 4322:score 126 Blue alliance:score 191 | LossBlue won | Watch |
Match 13| Match | Alliances | Result | Video |
|---|---|---|---|
 | Red alliance with 4322:score 76 Blue alliance:score 30 | WinRed won | Watch |
 | Red alliance with 4322:score 185 Blue alliance:score 40 | WinRed won | Watch |
 | Red alliance with 4322:score 119 Blue alliance:score 109 | WinRed won | Watch |
 | Red alliance:score 33 Blue alliance with 4322:score 50 | WinBlue won | Watch |
 | Red alliance with 4322:score 94 Blue alliance:score 114 | LossBlue won | Watch |
 | Red alliance:score 101 Blue alliance with 4322:score 147 | WinBlue won | Watch |
 | Red alliance:score 82 Blue alliance with 4322:score 55 | LossRed won | Watch |
 | Red alliance:score 100 Blue alliance with 4322:score 104 | WinBlue won | Watch |
 | Red alliance with 4322:score 151 Blue alliance:score 72 | WinRed won | Watch |
 | Red alliance with 4322:score 113 Blue alliance:score 133 | LossBlue won | Watch |
 | Red alliance with 4322:score 146 Blue alliance:score 103 | WinRed won | Watch |
 | Red alliance with 4322:score 124 Blue alliance:score 90 | WinRed won | Watch |
 | Red alliance:score 160 Blue alliance with 4322:score 100 | LossRed won | Watch |
 | Red alliance with 4322:score 117 Blue alliance:score 102 | WinRed won | Watch |
 | Red alliance:score 185 Blue alliance with 4322:score 65 | LossRed won | Watch |
 | Red alliance:score 188 Blue alliance with 4322:score 104 | LossRed won | Watch |
Match 13Repositories linked to this robot, read from GitHub: description, language, activity through the season, and the latest commit. Private repositories show as a plain link.
Posts by team members in our Open Alliance thread on Chief Delphi, newest first. Replies from other teams stay on Chief Delphi.
Off-Season Thread Come join us on our off-season build thread as we build a new robot with all new hardware and a new swerve library! 4322 Clockwork | 2025 Off-season Build Thread | Open Alliance
Come join us on our off-season build thread as we build a new robot with all new hardware and a new swerve library!
4322 Clockwork | 2025 Off-season Build Thread | Open Alliance
In Milstein quals 87, we scored 117 of the 119 points by our alliance, including 21 coral on L2/L3 and a deep climb!
In Milstein quals 87, we scored 117 of the 119 points by our alliance, including 21 coral on L2/L3 and a deep climb!
Central Valley Regional Update Alliance 6! Design During practice we encountered an issue with our hopper being way too bouncy, which led to inconsistency while intaking from the coral station. To…
Read moreAlliance 6!
During practice we encountered an issue with our hopper being way too bouncy, which led to inconsistency while intaking from the coral station. To fix this issue, we decided to add a static-balancing mechanism mounted to the top of our A frame.
The day before going to CVR, we tested our climber and practiced different methods of climbing, such as going into the cage at an angle. While we were experimenting with the climber, our eye bolt attaching the spool to the climber arm got bent. To avoid this problem in the future, we replaced the broken eyebolt with a denser and stronger one that was welded shut.
While practicing removing the climber from the cage post-match, we realized that our climber ratchet was too fragile for the weight of the entire robot.
To maximize our capabilities for CVR, we prepared an L1 mechanism inspired by team 190. Leveraging our vision alignment system, we optimized an initial sideswipe delay that reorients the coral horizontally into the trough following the maneuver. However, due to our robot’s geometry and in-game inconsistencies, the method seems to be unreliable without further changes to our robot.
In one of our qualification matches, a surprising incident occurred when we were intaking from the coral station. During one of our matches, our locking POE ethernet cable was disconnected after experiencing a heavy collision from a defensive robot. To avoid this situation, cables that were locked into our ports were hot glued.
4/1 Update Our robot can…… CLIMB??? Robot before: Robot Now: Finalists at Los Angeles Regional! Design Climber Our climber, inspired by Team 4481, has been successfully tested at a practice field…
Read moreOur robot can……
CLIMB???
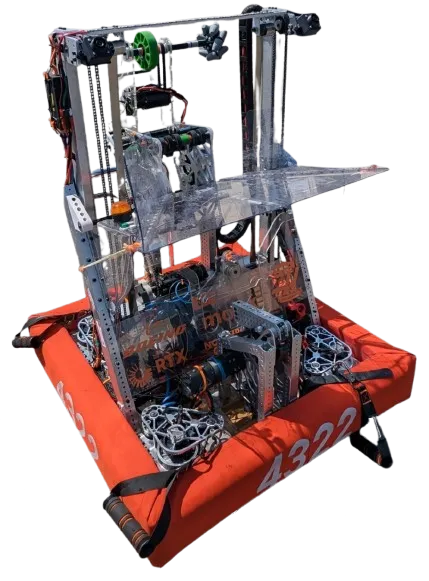
Robot before:
Robot Now:
Finalists at Los Angeles Regional!
Our climber, inspired by Team 4481, has been successfully tested at a practice field and is performing exceptionally well!
During the design process, we encountered an issue where the chain would collide with the top rail of our elevator. To resolve this, we implemented an optimized climber design that extends outside our frame perimeter. This adjustment shifts the robot’s center of gravity (CG) forward, away from the elevator, preventing interference.
To ensure the durability of our climber and support its motor, we integrated a ratchet system. A pair of rubber bands applies constant force to keep the pawl engaged with the gear, allowing the motor to rotate in only one direction. This prevents the robot from unintentionally lowering itself after climbing. When the arm needs to move in the opposite direction, a servo releases the pawl, enabling the gear to rotate freely as needed.
With our new climber design, the chain now rests along the robot’s CG axis, positioned directly beneath our funnel. To accommodate this, we split the funnel into two halves, connected by a pin. During the endgame, a linear servo releases the pin under constant tension from surgical tubing, allowing the funnel to separate about the hinge.
However, as expected, the two halves of the funnel were not perfectly balanced when reassembled. To address this, we implemented a hopper interlock to maintain alignment and stability.
Additionally, based on our experience at the Los Angeles Regional, we realized that having a coral between the robot and the coral station made intaking difficult and time-consuming. To improve efficiency, we adjusted the geometry of our hopper. Using physics calculations to predict the coral’s trajectory, we significantly lowered the hopper’s angle, which proved effective in practice today.
We are now able to load from the coral station even when one or two coral is in between the robot and the station!
With the addition of our climber, we had to remove weight from other areas of the robot to stay within the limit.
We also removed the y-tube, since now that we are splitting the intake in half, we don’t need that tube to structure our intake, instead we use the hinge to hold it in place.
Our robot now weighs 113.7 pounds—just 1.3 pounds under the limit!
Our elevator bearing blocks were heavily damaged and bent during the Los Angeles Regional. We replaced the damaged bearing blocks with our newly ordered ones, and reassembled our elevator.
Champs travel arrangements are complete. So much nicer than last year when we qualified week 6. That’s the one thing I’m not looking forward to about CA districts next year.
Champs travel arrangements are complete. So much nicer than last year when we qualified week 6. That’s the one thing I’m not looking forward to about CA districts next year.
 2 photos from “Build update”, Mar 28, 2025Post #66

Powered by The Blue Alliance
Off opens The Blue Alliance's normal site. Saved in this browser.